
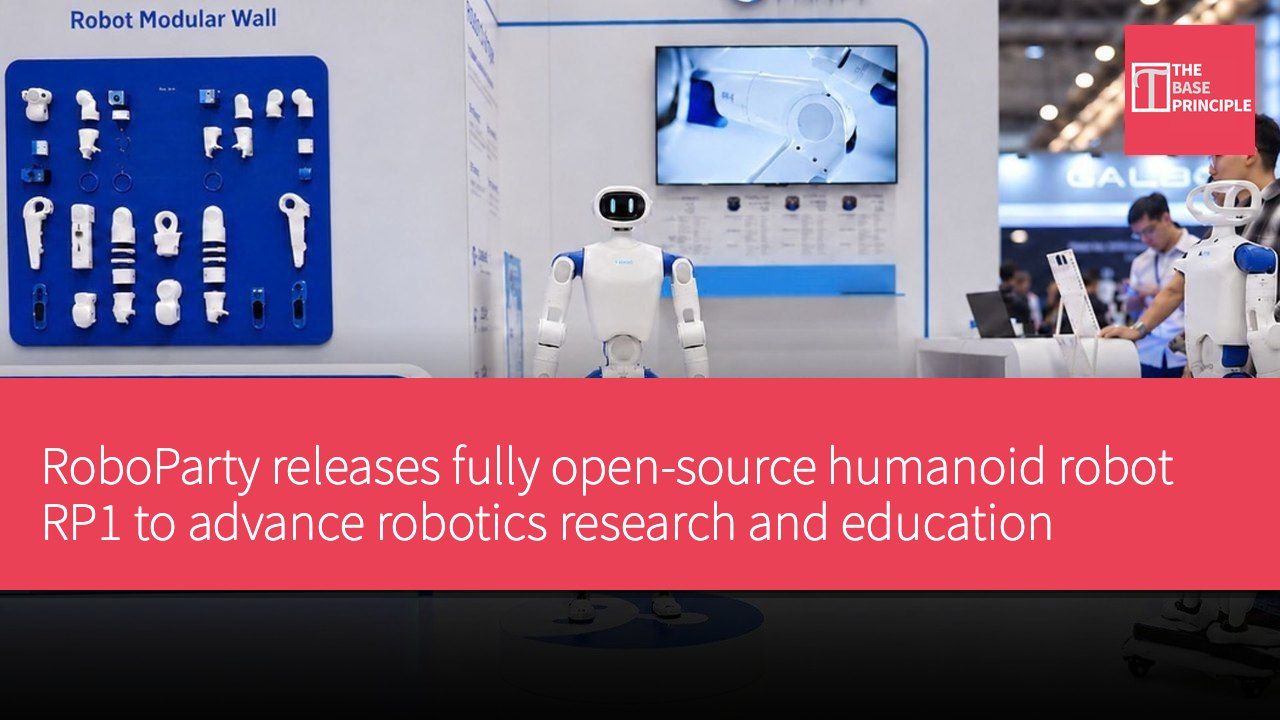
- RP1 is a fully open-source humanoid robot launched by RoboParty to advance robotics research and education.
- RP1 features dynamic stability, enabling it to handle external disturbances and recover balance.
- RoboParty plans to gradually open RP1's motion control system and related tools to foster developer collaboration.
- The company's global developer community has grown to over 5,000 members, spanning multiple academic institutions.
Chinese robotics company RoboParty has officially launched RP1, a full-stack open-source humanoid robot designed for robotics research, education, and the development of embodied artificial intelligence. The company first publicly demonstrated the bipedal robot on September 28, 2026, at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), using an interactive "Kick Me" display. The launch of RP1 is the latest outcome following RoboParty's launch in January 2026 of the open-source humanoid robot project RPO (ROBOTO ORIGIN), which has garnered over
2,500 stars on GitHub. The company describes RP1 as a high-performance platform aimed at providing researchers and developers with an open humanoid system.
RP1 Dynamic Stability Demonstration
At IROS 2026, RoboParty demonstrated the dynamic stability of its RP1 humanoid robot, using an interactive "Kick Me" display to test how the machine handles external disturbances. Visitors could push or kick the robot, and RP1 would adjust its posture to regain balance rather than simply executing pre-programmed movements. The demonstration was enabled by RoboParty's open research and development platform PartyOS, which integrates the company's UFO framework. UFO, or "Universal Framework for Unsupervised Reinforcement Learning of Humanoid Control," uses unsupervised reinforcement learning to train low-level motion policies for dynamic behaviors, including skill transitions, disturbance recovery, and fall recovery, allowing the robot to develop motion strategies beyond fixed trajectories.
RoboParty is integrating the RP1 robot body, drive modules, low-level control, and embodied AI algorithms into a single development system. This approach aims to enable hardware and software capabilities to be tested together rather than developed as independent components. The company also positions RP1 as a full-stack open-source humanoid platform. Beyond mechanical design and core drive modules, RoboParty plans to gradually open its motion control system, simulation environment, software development kit, and training tools, with the goal of giving researchers and developers better control over the entire humanoid robot stack, from hardware and low-level control to AI model training and deployment.
Open Platform Development Plan
The company stated that this platform aims to support reproducible research, algorithm development, and collaboration among humanoid robots.
RoboParty founder Huang Yi said: "We want RP1 to become an open foundation that developers can access, modify, train, and continuously improve. Full-stack open source has been our technical direction since the RPO project." RP1 is built around the hardware and software demands of dynamic humanoid robots, with peak joint torque reaching 160 Nm. Its architecture combines RoboParty's Romomo drive modules, mechanical structure, and real-time motion control system to support demanding locomotion, recovery, and extended development experiments.
The robot draws on technology from RoboParty's earlier projects: RPO established the company's open-source bipedal robot platform, Romomo introduced its own drive modules, and RP Hand extended the system to dexterous manipulation and human-robot interaction. These components are now part of RP1's broader development architecture.
RoboParty is also expanding PartyOS capabilities to cover humanoid walking, perception, whole-body manipulation, and autonomous robot intelligence. The platform aims to connect hardware-level systems with high-level AI development, enabling researchers to work across different parts of the robot stack. The company said its global developer community has grown to over 5,000 members, spanning research, education, and maker communities. Team members come from institutions including Tsinghua University, Peking University, Harbin Institute of Technology, Stanford University, Carnegie Mellon University, and Zhejiang University.
RoboParty plans to provide more details on the RP1 open-source roadmap in October 2026. The company expects to release additional software and hardware versions in the fourth quarter and launch mass production plans.
Impact of RP1 on Robotics Research
The launch of RP1 marks a significant advance in open-source humanoid robot technology, providing researchers and developers with a flexible platform. Through its open hardware and software architecture, RP1 not only fosters innovation in robotics technology but also strengthens collaboration between academia and industry. As the global developer community expands, RP1's influence will further grow, driving the application of robotics technology in education and practical use.