
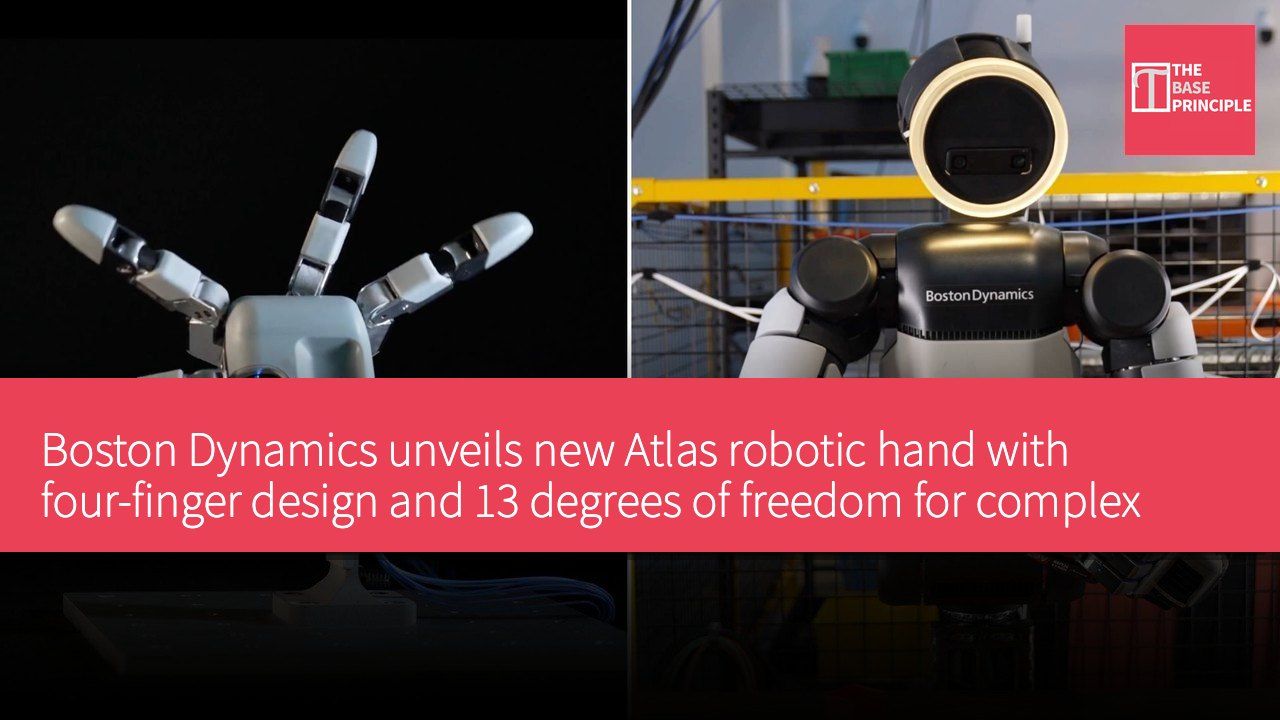
- The Atlas robotic hand features four fingers and 13 degrees of freedom, designed for complex tasks.
- The new hand's design increases joint degrees of freedom, enhancing control over objects.
- The absence of a fifth finger reduces cost and failure points while still meeting manipulation needs.
- The design accounts for AI training, optimizing the transition between simulation and reality.
Humanoid robots are increasingly being designed to work in environments built for humans, but mimicking the human body does not mean replicating every part. Boston Dynamics has taken this approach with its latest Atlas robotic hand, which features four fingers and 13 degrees of freedom rather than attempting to recreate a traditional five-finger hand. The company says the new hand's design revolves around a set of difficult-to-balance requirements: dexterity, strength, durability, sensing capability, manufacturability, and the ability to train robotic behaviors in simulation. The end result is a hand that does more than just grasp objects — it can manipulate them, recover from slips, and operate tools.
Increasing degrees of freedom and control capability
The new hand's design raises Atlas's joint count from the previous seven degrees of freedom to 13. It uses four fingers, including a more capable opposable thumb, with the other three fingers each having three degrees of freedom while the thumb has four. The company says this configuration allows the fingers to spread and provides greater control over individual fingertips. The joints use direct drive and a single actuator type, with actuators encapsulated so they do not rely on cables crossing the joints. The hand is roughly the size of a large human hand, an important constraint because Atlas is intended to work with human-scale tools and equipment.
Boston Dynamics also says the hand maintains enough strength for demanding physical work. The company reports it can lift a loaded mini-fridge weighing more than 100 pounds, aligning with the broader Atlas platform's focus on industrial material handling. The production Atlas itself has a peak payload of 110 pounds and a sustained payload of 66 pounds.
The missing fifth finger is one of the more unusual aspects of the design. Boston Dynamics notes that adding a pinky would be relatively simple, but the team tested whether it was actually necessary for the tasks the robot is expected to perform. The company concluded that four fingers already provide in-hand object reorientation, recovery from slip grasps, and the ability to manipulate tools while pressing triggers. Adding another finger would require three additional actuators, increasing the hand's cost, size, and potential failure points. This trade-off is especially important for an industrial robot expected to perform repetitive manipulation, not just demonstrate dexterity in a lab.
Considerations for AI training
The new hand's design also accounts for AI training. Its mechanical design has been optimized for high-fidelity simulation and sim-to-real reinforcement learning, so that control policies trained in simulation can transfer to physical hardware. The hand uses a backdrivable transmission, meaning external forces can drive the joints rather than being resisted by a rigid, high-friction mechanism. This allows Atlas to use proprioception — sensing the position and movement of its own joints — as part of its control system. The hand also includes dense pressure-sensitive tactile sensors covering the fingertips and palm.
These sensors complement proprioception by providing information about contact with objects. The robotics company says the combination of backdrivable hardware and a control system designed to compensate for effects like friction and motor cogging enables the hand to be modeled with high dynamic fidelity. Reinforcement learning systems can be exposed in simulation to variations in motor behavior, surface friction, object geometry, and disturbances, then test the resulting policies on the physical robot.
At the core of the design is the distinction between grasping and manipulation. Traditional industrial grippers work very well when the item, orientation, and work cell are tightly controlled. Humanoid robots, however, are meant to interact with a broader range of objects and workspaces. The company notes the new hand can perform a variety of dexterous behaviors, including pinch grasps between the thumb and individual fingers, tripod grasps, and controlled thumb motion between the other fingers. It is also designed to handle tools such as drills, grinders, nail guns, torque drivers, and welding torches. This capability may become especially important as humanoid robots move beyond simple material handling.
Atlas is already being developed in industrial settings, with Boston Dynamics and Hyundai training the robot on manufacturing and logistics tasks at a dedicated facility in Georgia. The new hand does not attempt to replicate every capability of the human hand, instead betting that a simpler, stronger, and highly controllable design can provide enough dexterity to perform useful physical work while remaining suitable for simulation, maintenance, and eventual mass production.
Dexterity and practicality in robotic hand design
Boston Dynamics' Atlas robotic hand emphasizes dexterity and practicality in its design. The four-finger design not only reduces cost but also improves operational efficiency. This design allows the robotic hand to adapt to a variety of work environments, thereby expanding its application scope. As AI technology advances, the hand's design also accounts for simulation training needs, enabling it to execute complex tasks in real-world environments. These characteristics give Atlas greater potential in the fields of industrial automation and humanoid robotics.