
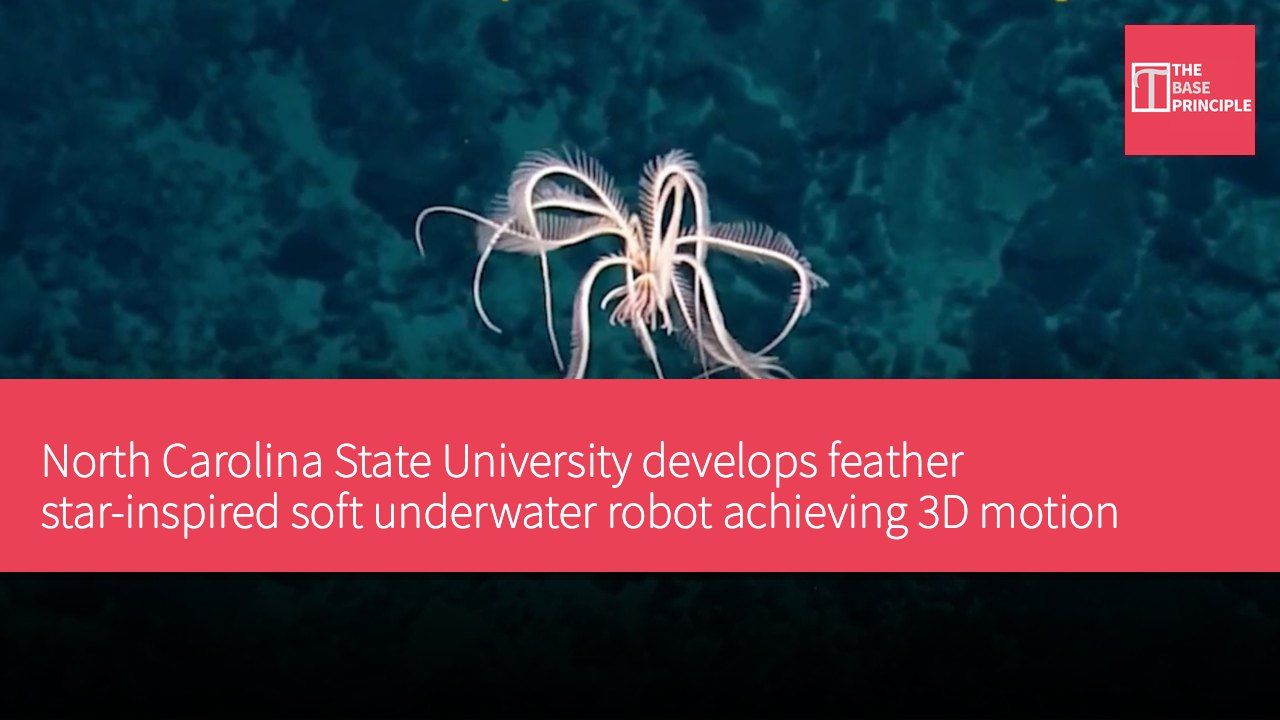
- The soft underwater robot is inspired by the feather star and can move in three-dimensional space.
- The robot requires only two actuators, reducing mechanical complexity and control demands.
- The design includes multiple locomotion modes, enhancing underwater operational flexibility.
- Future work will develop a wireless version and explore potential applications.
Researchers at North Carolina State University have developed a soft underwater robot inspired by the feather star, a marine invertebrate. The robot can move in three-dimensional space, including forward and backward, up and down, and rotation around its axis. It achieves this range of motion using only two actuators, offering greater efficiency compared to the six actuators typically required for conventional three-dimensional motion. This design leverages "mechanical intelligence," relying on the robot's structure and interaction with water to reduce the control inputs needed.
This feather star robot achieves three-dimensional motion with just two actuators, reducing the mechanical complexity typically required. Inspired by the feather star, which coordinates its limbs to move and hover in different directions, the robot features four elastic wings arranged around a central disc. These wings are monostable, meaning they bend under actuation but automatically return to their original position when the applied force is removed. This mechanical design enables the robot to generate multiple gaits without needing a dedicated actuator for each direction.
Robot Locomotion Modes
According to the NCSU team, the system is based on the principle of "mechanical intelligence," where the robot's physical structure helps determine its behavior and reduces the control inputs required from a computer or human operator. Conventional systems typically require at least six actuators to achieve similar three-dimensional motion. "The exciting thing about this work is that it demonstrates how intelligent design can be used to create robotic devices with a remarkable range of motion using a minimal number of actuators," said Jie Yin, professor of mechanical and aerospace engineering at NCSU and corresponding author of the study, in a statement.
The robot's two actuators are housed within its central disc and control all four wings. When both actuators are activated simultaneously, the wings snap downward rapidly. Once the actuators turn off, the elastic wings spring back upward. Rapidly repeating this cycle enables the robot to flap its wings and swim upward. When the wings flap more slowly, the robot can hold its position and hover, a mode the researchers call "jellyfish mode." The same hardware can also achieve horizontal locomotion by changing how the actuators are controlled. Activating only one actuator causes a single wing to flap like a caudal fin, propelling the robot forward or backward, a gait the researchers dub "fish mode."
Additionally, the robot can rotate around its central axis. By rapidly alternating the two actuators, the researchers generate asymmetric wing motion that causes the robot to spin. This "rotor mode" provides directional control, allowing the robot to steer underwater.
Design Flexibility and Applications
These three locomotion modes enable the soft robot to control vertical, horizontal, and rotational movement. The researchers demonstrated the system's ability to explore underwater environments using a camera and to lift objects independently or collaboratively. The design builds on the team's earlier work involving a manta ray-inspired underwater robot that could traverse water quickly but lacked comparable three-dimensional agility. Rather than adding more motors and complex mechanisms, the researchers sought to gain additional locomotive capabilities through the robot's physical structure. The team notes that this compact design can serve as a platform for underwater robotic applications, particularly where agility and mechanical simplicity are paramount.
Future work will focus on developing a fully wireless version and exploring potential applications with researchers in other fields.
How Mechanical Intelligence Is Changing Underwater Robot Design
The design of this soft underwater robot demonstrates the potential of mechanical intelligence, significantly improving locomotive efficiency by leveraging physical structure to reduce actuator requirements. Compared to conventional systems, achieving multiple gaits with just two actuators not only lowers mechanical complexity but also enhances underwater operational flexibility. This innovative design not only adapts to diverse underwater environments but also provides a foundation for future wireless versions and other applications, underscoring its significance in the field of underwater robotics.