
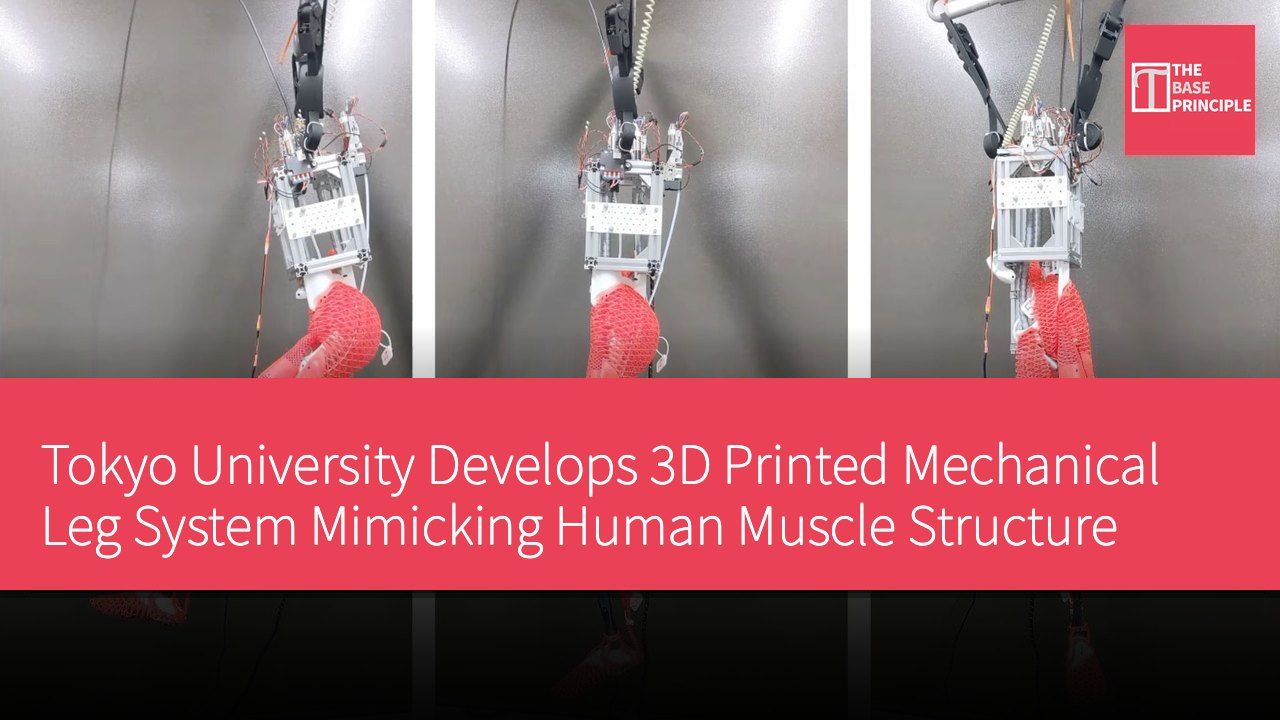
- The mechanical leg system developed by Tokyo University mimics human muscle structure using 3D printing technology.
- The system utilizes thermoplastic polyurethane material to create components with different mechanical properties.
- The movement of the mechanical leg is driven by motors and cables, requiring external support to demonstrate walking.
- Challenges exist in the manufacturing and control processes, needing to overcome material reactions and friction issues.
Researchers at Tokyo University have developed a life-sized mechanical leg system that utilizes a 3D printed structure inspired by human muscles, tendons, and ligaments. The design employs a flexible plastic material, allowing each component to possess unique mechanical properties through varying printing geometries. These structures provide muscle-like elasticity, tendon stiffness, ligament support, and cushioning in the foot, with leg movements driven by motors and cables. While the prototype can demonstrate walking with external support, achieving independent locomotion remains a challenge for future development.
Flexibility of the Mechanical Leg System
This life-sized mechanical leg system utilizes a flexible structure created through 3D printing, replicating some mechanical properties of human muscles, tendons, and ligaments. The system employs a thermoplastic polyurethane (TPU) material, allowing different structures to exhibit varying flexibility, stiffness, and mechanical support through different printing geometries. Instead of using different materials for each component, researchers leverage adjustable printing patterns to create muscle-like elastic structures, stiffer tendons, ligaments that restrict joint movement, and cushioning in the foot. This approach simplifies the design and manufacturing of musculoskeletal robots by integrating various mechanical properties into a single material system.
According to the team, the project explores how the mechanical behavior of robotic body parts can be controlled through their geometries. Researchers adjusted parameters such as lattice density and pillar thickness to control how individual TPU structures respond to mechanical forces. These adjustments enable the same material to produce components with different mechanical properties. Softer printed areas exhibit elasticity similar to muscle, while denser or thicker structures provide greater stiffness associated with tendons. The team also created ligament-like components using patterned structures to limit the movement of hip, knee, and ankle joints, providing mechanical constraints without relying on traditional bearings.
The foot incorporates cushioning properties, adding another functionality to the same material manufacturing method.
By adjusting geometries, researchers can transition between softer and harder areas within the printed structures, reducing the need for developing and manufacturing independent material systems for each robotic skeletal component. However, TPU structures do not actively contract like biological muscles. Instead, they deform when external forces are applied, providing passive elasticity and mechanical compliance.
Cable-Driven Motion System
The cable-driven mechanical legs consist of an electric actuation system mounted on a pelvic frame, which includes motors and pulleys. These motors pull cables to the printed muscle structures via Bowden cables, generating the motion required to operate the legs. Positioning the motors higher in the body helps reduce the weight borne by the lower limbs. This is relevant to the design of legged robots, as additional mass in the legs increases the mechanical demands of movement. The combination of electric-driven cables and flexible printed structures separates the system's active and passive functions. The motors generate the necessary motion forces, while the TPU components provide elasticity, stiffness, and structural constraints.
This arrangement allows researchers to study the interactions of different compliant structures in coordinating leg movements. In the demonstrated walking experiments, the mechanical system used external suspension to support part of its weight and limit trunk rotation. The legs moved according to preset cable lengths, enabling researchers to examine coordinated walking motions without first addressing the more complex issue of maintaining balance. Therefore, the demonstration did not prove that the robot could walk independently or maintain balance without external assistance.
Challenges in Manufacturing and Control
Manufacturing and control also present challenges. Producing a single printed muscle structure takes approximately 20 to 40 hours. Cable friction and changes in the mechanical response of materials under repeated loads further complicate the control process. The researchers' approach offers a shared manufacturing method for producing different compliant components, but integrating these components into a reliable, independently walking robotic system remains a significant engineering challenge. A direct contribution is a parametric design and manufacturing method capable of producing various musculoskeletal structures from a single flexible material, providing a way to establish different mechanical properties within the robot's body without relying entirely on traditional rigid components and independent materials.
Future Challenges for Mechanical Leg Technology
The development of this technology demonstrates how 3D printing can create mechanical structures that mimic human muscles, which is crucial for advancing future robotics technology. Although the current system can demonstrate basic movements, achieving independent walking still faces numerous engineering challenges, including the mechanical responses of materials and the complexities of control. These challenges not only affect the performance of the robot but also limit the potential for future applications. Successfully overcoming these issues will lay the groundwork for the practical implementation of robotic technology and may open new possibilities for applications across various fields.